NT-Pulse
Long-Range, Ultra High Resolution Software Defined Imaging Radar
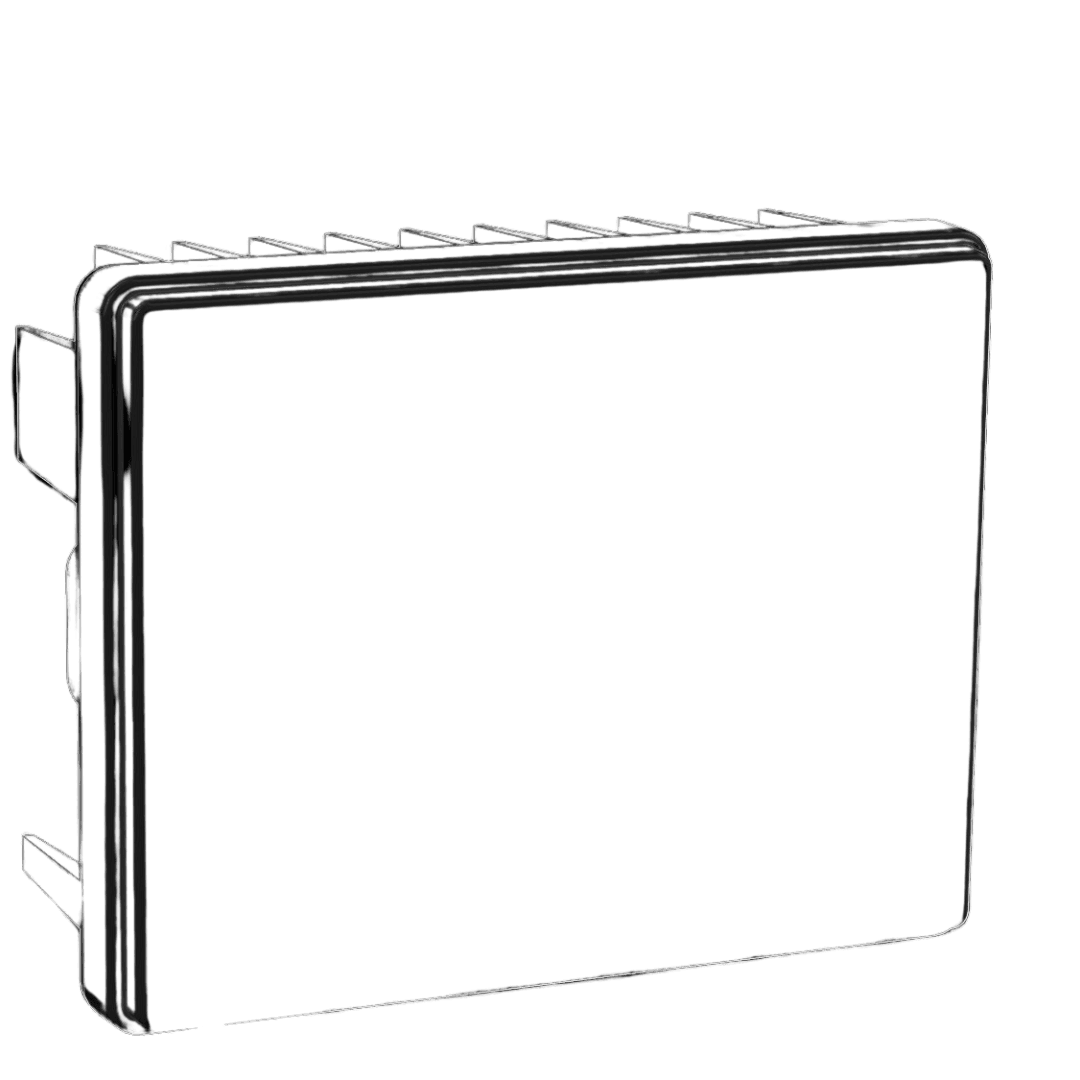
NT-Pulse enables next-generation radar sensing systems by providing a breakthrough combination of resolution, range, point density, size, cost and software flexibility.
NT-Pulse delivers highly dense 4D point clouds with excellent performance in a compact size for radar-based perception, classification, mapping, tracking, and autonomous navigation. Its rugged solid-state architecture allows reliable operation in rain, fog, dust, snow, and other harsh environments.
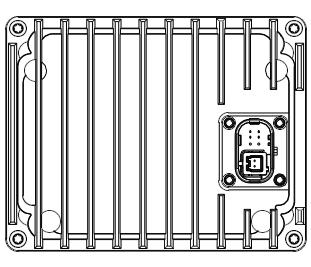
Highlights
- Industry leading resolution without compromise to doppler or range performance
- 1.5° static angular resolution with 2nd-gen advanced beamformer
- Zadar SDK supports dynamic radar reconfiguration and performance optimization
- Robust against in-band interference
- Optional automotive ethernet or PoE
Mobile Applications (77GHz)
- Next-gen ADAS
- Fully autonomous driving
- Mining and construction
- Industrial and agricultural
Configuration Options
| Power & Interface | Long range antenna — 120° × 24° FOV, 800m car detection | Wide FOV antenna — 120° × 50° FOV, 350m car detection | Ultra-wide FOV antenna — 120° × 90° FOV, 250m car detection |
|---|---|---|---|
| 12V DC / 1000 BASE-T1 — automotive and robotics | NT-Pulse-T1-LR | NT-Pulse-T1-W | NT-Pulse-T1-U |
| Power over Ethernet / RJ45 — infrastructure and evaluation | NT-Pulse-POE-LR | NT-Pulse-POE-W | NT-Pulse-POE-U |
Radar Detection Performance
| Antenna Configuration | Long range | Wide FOV | Ultra wide FOV |
|---|---|---|---|
| Field of View (H × V) | 120° × 24° | 120° × 50° | 120° × 90° |
| Static Angular Resolution | 1.5° | 1.5° | 1.5° |
| Angular Accuracy (H × V) | ±0.25° | ±0.25° | ±0.25° |
| Truck Detection | >400 m | >400 m | >250 m |
| Car Detection | >400 m | >350 m | >250 m |
| Human Detection | >200 m | >130 m | >85 m |
| Instrumented Range Max. | 0.1 – 400 m | 0.1 – 400 m | 0.1 – 250 m |
| Range Resolution Min. | 0.033 m | 0.033 m | 0.033 m |
| Range Accuracy Min. | 0.01 m | 0.01 m | 0.01 m |
| Doppler Ambiguity Max. | 143.4 m/s (516 km/h) | 143.4 m/s (516 km/h) | 143.4 m/s (516 km/h) |
| Doppler Resolution Min. | 0.08 m/s | 0.08 m/s | 0.08 m/s |
| Frame Time | 40 ms / 25 Hz | 40 ms / 25 Hz | 40 ms / 25 Hz |
- Field of view is based on 6dB antenna beamwidth in azimuth and elevation.
- Truck detection range: 28 dBsm typical pickup truck RCS in obstruction-free real-world scenario, >90% detectability. Car detection range: 20 dBsm typical sedan RCS, >90% detectability. Pedestrian detection range: -2 dBsm typical human RCS, >90% detectability.
- Custom radar operational modes can be applied upon request to increase the maximum instrumented range beyond the advertised limits.
- Range resolution and accuracy are for high point cloud density optimized modes; doppler ambiguity and resolution are for doppler optimized modes.
Hardware Specifications
| Configuration | 12V / 1000BASE-T1 Edition | PoE / RJ45 Edition |
|---|---|---|
| Frequency | 77–81 GHz Worldwide | 77–81 GHz Worldwide |
| Certification | FCC Part 15 pending | FCC Part 15 pending |
| Radio Principle | Cascaded SDIR with RF-FMCW modulation and 2nd gen HiRes Beamformer | Cascaded SDIR with RF-FMCW modulation and 2nd gen HiRes Beamformer |
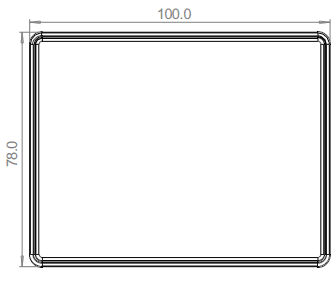
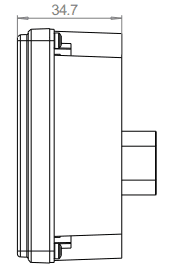
| Dimensions | 100 × 78 × 35 mm | 100 × 78 × 35 mm |
| Weight (Preliminary) | 200 g (7.0 oz) | 240 g (8.5 oz) |
| Mounting (Preliminary) | Back: 4× M4 screws; Top: 2× M2.5 screws, 2× locating 2mm pin holes | Back: 4× M4 screws; Top: 2× M2.5 screws, 2× locating 2mm pin holes |
| Material | Polycarbonate + 6061-T6 Aluminum Black Anodized | Polycarbonate + 6061-T6 Aluminum Black Anodized |
| Operating Temperature | -40° – 85°C | -40° – 85°C |
| Storage Temperature | -40° – 95°C | -40° – 95°C |
| Weather Sealing | IP68 2-meter | IP67 |
| Interface | 1000BASE-T1 | 1000BASE-T over RJ45 |
| Connector | 6-pin JAE MX44 Automotive Header | Sealed RJ45 |
| Power Supply | +9–24 V DC, 12 V nominal | 802.3bt Type 3 (PoE++) |
| Power Consumption | 10 W average, 15 W peak | 10 W average, 15 W peak |
| Synchronization | IEEE 1588 PTP, gPTP | IEEE 1588 PTP, gPTP |
| IMU Output | 3 axis gyro, 3 axis accelerometer, 208 Hz sampling (STMicroelectronics ASM330LHH) | 3 axis gyro, 3 axis accelerometer, 208 Hz sampling (STMicroelectronics ASM330LHH) |
- Each edition is available in three antenna types: Long Range, Wide FOV and Ultra-wide FOV.
Modes For Dynamic Platforms
| Mode Configuration | 2 | 3 | 5 | 7 |
|---|---|---|---|---|
| Max Range | 30 m | 85 m | 250 m | 400 m |
| Minimum Range | 0.05 m | 0.1 m | 0.3 m | 0.5 m |
| Range Resolution | 3.3 cm | 8.9 cm | 26.2 cm | 41.9 cm |
| Doppler Ambiguity | 74.4 m/s | 143.4 m/s | 143.4 m/s | 143.4 m/s |
| Doppler Resolution | 0.079 m/s | 0.145 m/s | 0.145 m/s | 0.145 m/s |
| Static Angular Resolution | 1.5° | 1.5° | 1.5° | 1.5° |
| Angular Accuracy | ±0.25° | ±0.25° | ±0.25° | ±0.25° |
| Frame Time | 50 ms | 50 ms | 50 ms | 50 ms |
- Field of view per antenna: 120° × 24° (LR), 120° × 50° (W), 120° × 90° (U).
- The platform speed needs to be less than ¼ of the provided range for Doppler Ambiguity, otherwise the reported platform velocity might be folded. Modes 7 and 8 are unavailable for the ultra-wide FOV.
Related products
Enquire about the NT-Pulse
Tell us your lane count, read range or volume and we’ll quote the right configuration.